Four directions, one goal — robots that perceive, learn, decide and act in the real world.
Robotics
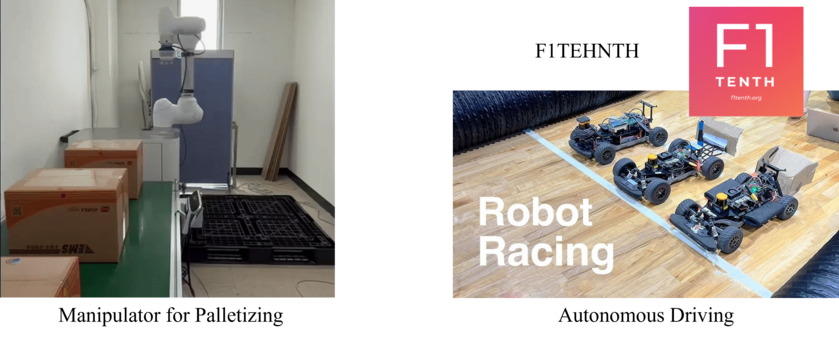
We bring our advances in reinforcement learning and computer vision onto real robotic systems, from mobile platforms to factory floors.
- Mobile Vehicles
- Autonomous Vehicle System
- Manipulators (Robot Arms)
- Manufacturing System
Deep Learning Vision
Perception
Reading the scene
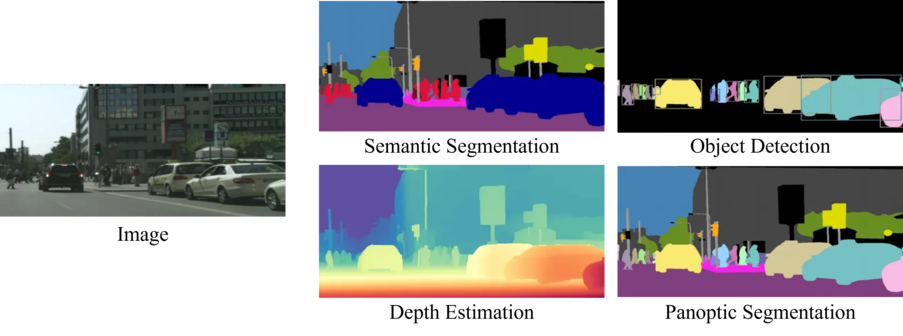
Dense understanding of what is around the robot — what objects are there, where they are, and how far away.
- Semantic Segmentation
- Depth Estimation
- Object Detection
- Panoptic Segmentation
Robust Vision
Holding up outside the lab
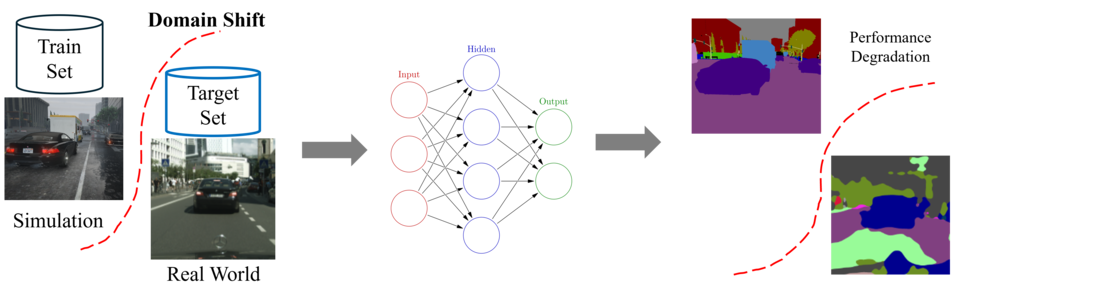
Rain, night, fog and unfamiliar sites break models trained on clean data. We make perception survive that gap.
- Image Restoration
- Domain Adaptation
- Domain Generalization
Efficient Vision
Running on the robot itself
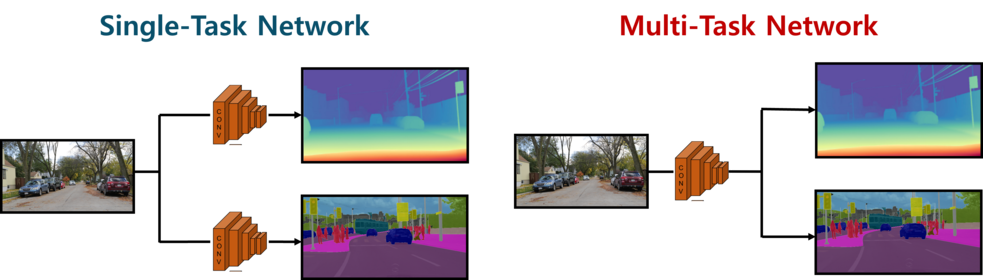
Robots carry limited compute. We keep accuracy while cutting the cost of running it.
- Multi-Task Learning
- Knowledge Distillation
Autonomous Driving
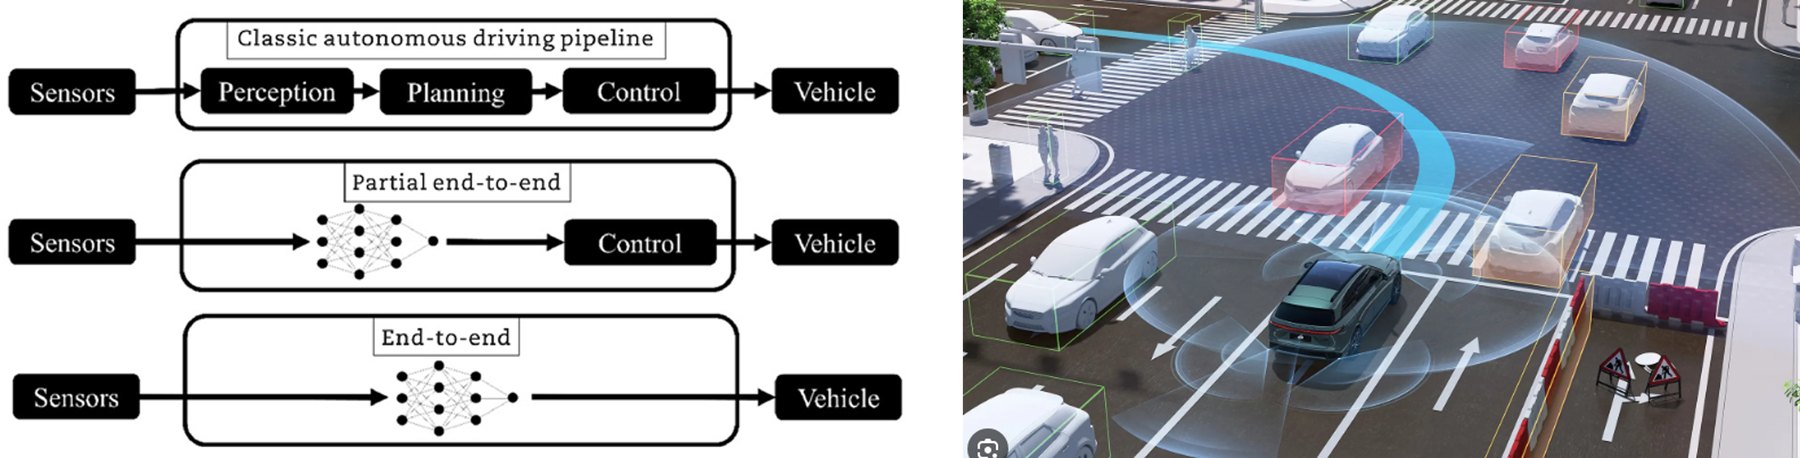
Instead of hand-wiring perception, planning and control into separate modules, we learn driving policies directly from multi-modal sensor input.
- End-to-End Policy Learning
- Safety-Aware Driving
- Multi-Modal Fusion (Camera / LiDAR / IMU)
- Sim-to-Real Transfer
Reinforcement Learning
Imitation Learning
Learning from demonstration
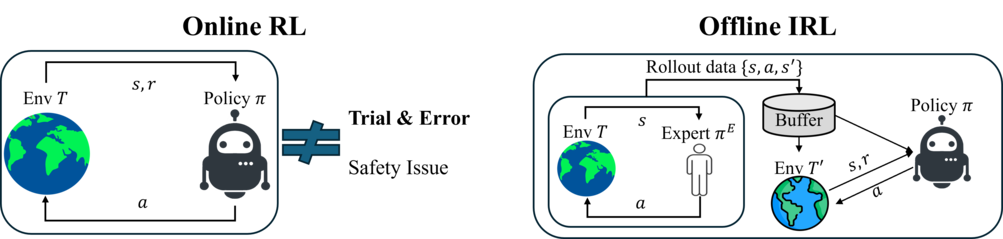
Agents that pick up expert behaviour from recorded human demonstrations instead of millions of trial-and-error episodes.
- Behavior Cloning
- Offline RL
- Inverse RL
Embodied AI
Transferring across bodies
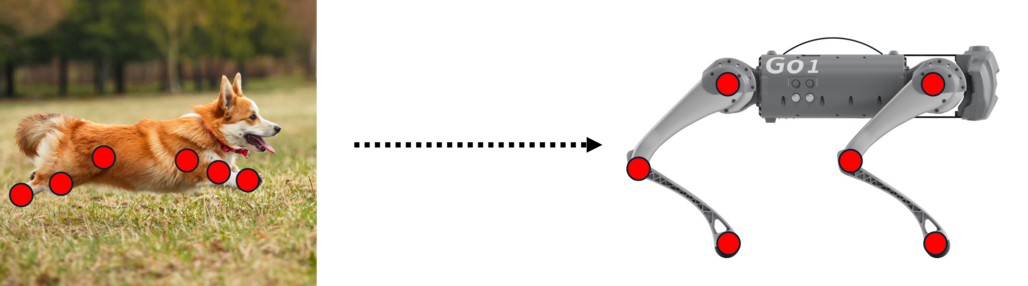
A policy learned on one robot should not be thrown away when the hardware changes.
- Cross Embodiment
- Domain Randomization
- Model Approximation